How to Choose a Linear Motor Controller?
Choosing a linear motor controller is not simply a matter of matching voltage and current. The controller must work with the motor, amplifier, feedback device, and machine mechanics. A poor match can cause vibration, heat, positioning errors, or unexpected downtime. This guide explains how to evaluate each requirement before purchasing.
Real-world testing often reveals details that product sheets overlook. Check continuous and peak current, bus voltage, encoder compatibility, communication protocols, and thermal limits. Pay close attention to acceleration demands. A small laboratory stage may need different control performance than a high-speed inspection system. The selected linear motor controller should also support the required tuning method, protection functions, and software environment. Clear documentation matters.
Experience shows that installation conditions can change the decision. Cable length, electrical noise, cabinet airflow, and grounding quality all affect performance. Ask the manufacturer for test data, wiring guidance, and verified compatibility. Independent reviews can help, but they should not replace engineering checks. I have seen projects focus too heavily on maximum speed, then struggle with heat and unstable tuning. That mistake is easy to repeat.
Think beyond the purchase price. Consider commissioning time, maintenance access, spare parts, and technical support. A controller with fewer features may be more reliable for a simple application. A complex machine may need advanced synchronization and safety integration. This article will compare these factors and outline a practical selection process. Leave room for testing. Final decisions should follow measured results, not assumptions.
Define the Role and Requirements of a Linear Motor Controller
How to Choose a Linear Motor Controller?
Define the Role and Requirements of a Linear Motor Controller
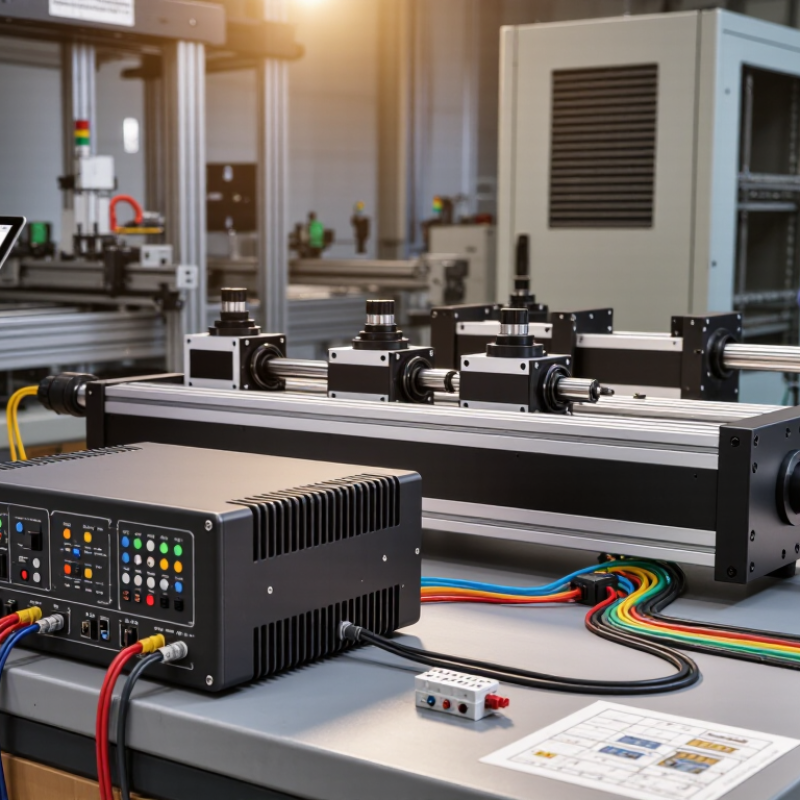
A linear motor controller is the system’s motion decision-maker. It converts position, speed, and force commands into controlled electrical output. The controller also reads feedback from encoders, scales, or force sensors. Without accurate feedback, a fast actuator can overshoot the target or create vibration.
Begin with the application’s real demands. Record stroke length, payload, peak force, continuous force, acceleration, duty cycle, and positioning accuracy. Include the moving mass, cable drag, and thermal conditions. These details matter more than impressive peak-speed figures. The International Federation of Robotics reported 541,302 industrial robot installations in 2023. This growth increases demand for repeatable, coordinated motion in compact equipment.
Check the controller’s control loops and communication features. Position, velocity, and current loops should match the motor’s feedback resolution. Network timing must support synchronized axes and predictable latency. The International Energy Agency estimates that electric motor systems consume roughly half of global electricity. Efficient tuning therefore affects operating cost, not only performance.
In commissioning work, engineers often overlook heat buildup during repeated acceleration. That mistake can cause gradual position drift. A laboratory test may pass. Production may not. Specify overload limits, emergency stopping behavior, enclosure protection, and service access before selecting hardware. A controller that meets every peak specification can still fail when its continuous rating is too low.
Match Electrical Ratings with the Linear Motor
A linear motor controller must match the motor’s electrical ratings, not just its advertised force.
Check the motor’s continuous and peak current first. A controller rated for 10 A continuous and 20 A peak may overheat during repeated acceleration. Compare those values with the motor datasheet, then review the duty cycle, ambient temperature, and cooling method.
Voltage matters too.
The controller’s bus voltage should suit the motor’s back-EMF at maximum speed. A mismatch can reduce travel speed or create dangerous overvoltage during deceleration. IEC 61800-2 defines key drive-system rating principles, while IEC 61800-5-1 addresses electrical safety. These standards are useful references, but they do not replace application testing. Real machines often behave differently.
Force constants also need attention.
A motor requiring 4 N/A will need 12.5 A to produce 50 N, before friction and acceleration loads. Leave practical headroom, perhaps 20% to 30%, for those losses. The U.S. Department of Energy reports that motor-driven systems consume about 70% of industrial electricity, so small efficiency errors can become expensive. Still, this estimate covers broad motor systems, not every linear application. That distinction is easy to miss.
Encoder voltage, feedback type, and commutation settings must match the controller.
Test the cold and fully warmed motor. Thermal limits can change the result. Never trust a nominal rating alone.
Evaluate Feedback, Motion Accuracy, and Performance
Choosing a linear motor controller starts with feedback, not advertised speed. A controller must know where the carriage is. Optical scales provide fine position data, while magnetic sensors often tolerate dust better. Match feedback resolution to the application. A microscope stage may need nanometer-level repeatability. A packaging slide may only need micrometers. More resolution is not automatically better. It can expose vibration that the mechanical frame cannot control. That lesson is easy to miss.
Check the complete feedback chain. Ask about sampling rate, signal noise, latency, and encoder interpolation. During commissioning, I watch position error while the axis moves through short, repeated strokes. A smooth graph matters. So does recovery after a sudden stop. If error spikes near the travel limit, the controller may need better tuning or a stiffer structure. Do not judge accuracy from one stationary reading. Motion accuracy includes settling time, overshoot, repeatability, and performance under changing loads.
Performance also depends on current control, update frequency, thermal capacity, and communication stability. A controller that moves an unloaded stage perfectly may struggle with a vertical payload. Test the real mass, cable routing, duty cycle, and acceleration profile. Leave headroom. I record temperatures after several hours, then compare them with the initial test. My early measurements are sometimes too optimistic. Rechecking them has prevented unreliable settings. Noise, resonance, and imperfect alignment deserve attention before final selection. Measured behavior matters more than impressive specifications.
Check Compatibility, Integration, Safety, and Long-Term Support
How to Choose a Linear Motor Controller?
Check Compatibility, Integration, Safety, and Long-Term Support
A linear motor controller must match the motor’s voltage, current, feedback device, and travel profile. Check continuous and peak force ratings, not only the advertised output. In commissioning work, encoder mismatches often cause hunting, noise, or unexpected position errors. Confirm feedback resolution, communication protocols, tuning tools, and cable requirements before ordering. The International Federation of Robotics reported 541,302 industrial robot installations in 2023. This growth increases integration pressure, especially where motion systems share networks and safety circuits.
Safety needs practical verification. Choose a controller that supports suitable torque-off functions and follows IEC 61800-5-2 principles. Review the machine risk assessment under IEC 60204-1. Ask for test records, fault behavior, and reset conditions. Documentation matters. So does support. Check firmware history, spare-part availability, repair procedures, and service response times. Long support claims can still be vague. Request written commitments. A perfect checklist does not exist.
Tips: Test the complete motor, controller, encoder, and load together. Measure heat after repeated acceleration cycles. Keep a spare cable and configuration file. Do not assume factory settings are safe for your machine. Compare real cycle data, not brochure figures. If integration feels rushed, stop and recheck the assumptions.
How to Choose a Linear Motor Controller?
Compare the main selection factors before choosing a linear motor controller. The priority scores reflect practical evaluation importance: compatibility and safety should be verified first, followed by integration, performance, and long-term support.
Check motor voltage and current ratings, feedback support, communication protocols, motion-control functions, protective features, documentation, spare parts, and firmware support before final approval.